
LEARNING PATH 01 · 25 GUIDES
Collaborative robots
Plan a cell, size its tools, teach accurate paths and validate the complete application.
Start with: Basic mechanics, SI units and a robot simulator. Hardware exercises require trained supervision and the manufacturer’s procedures.
A collaborative-capable arm does not make an application safe. Assess the complete cell, tool, part and foreseeable misuse. Never use these educational calculations to set certified safety limits. Apply the relevant standards and manufacturer instructions with a competent integrator.
From foundations to a working test
25 practical guidesChoose a first cobot task with a cycle-time worksheet
Start with a repeatable transfer between two fixed locations, not a complete factory process. Break the task into movements, gripping, inspection and…
Read the practical guide ↗
Calculate cobot payload including the gripper and adapters
A robot lifts the complete assembly on its flange, not just the saleable part. A payload worksheet prevents a common selection mistake: spending nearly…
Read the practical guide ↗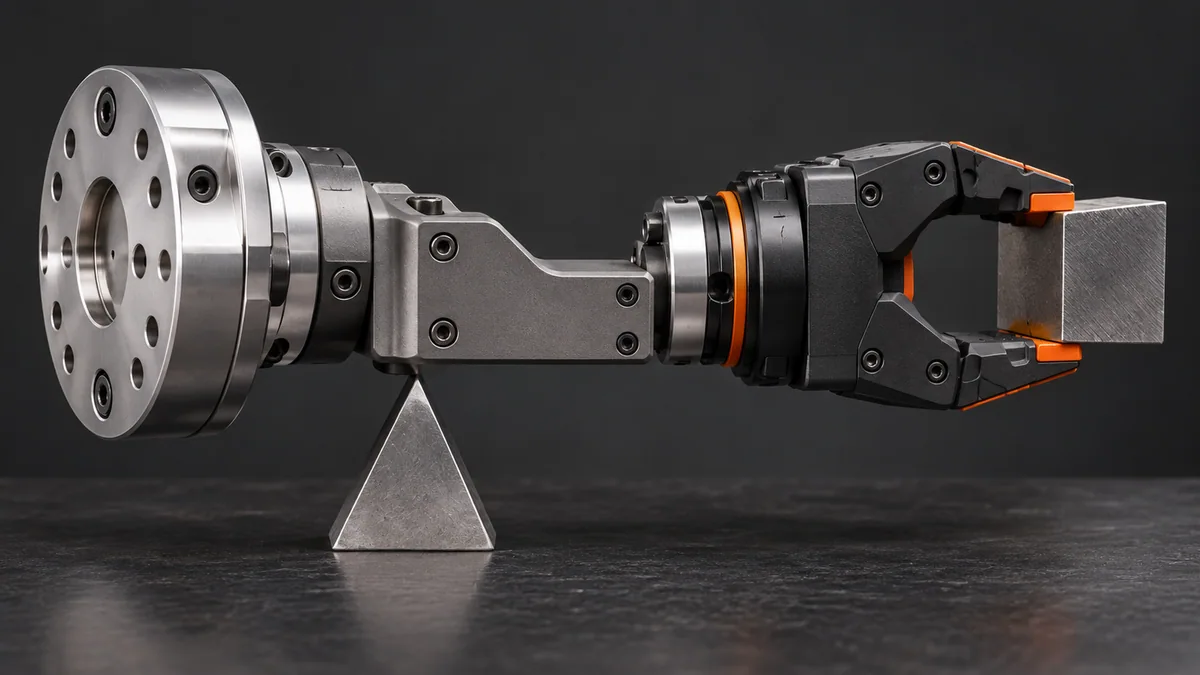
Find the center of gravity of a cobot tool
The same mass becomes harder to accelerate when it sits farther from the wrist. Locate the combined center of gravity before configuring a tool. Start…
Read the practical guide ↗
Check cobot reach before placing the robot base
A target inside the nominal reach sphere may still be impossible with the required tool orientation. Use a quick distance calculation to reject obviously…
Read the practical guide ↗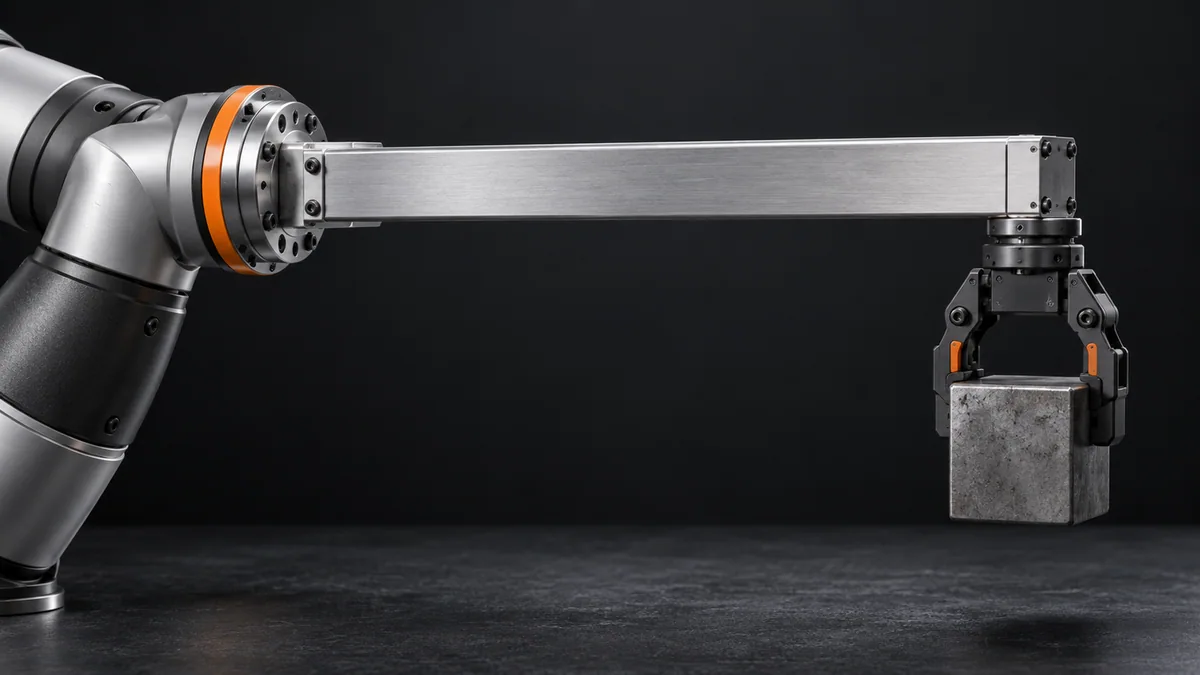
Estimate wrist bending moment from an offset payload
A long gripper adapter can be more problematic than a heavier compact tool. Estimate the static moment to compare candidate designs, then use the robot’s…
Read the practical guide ↗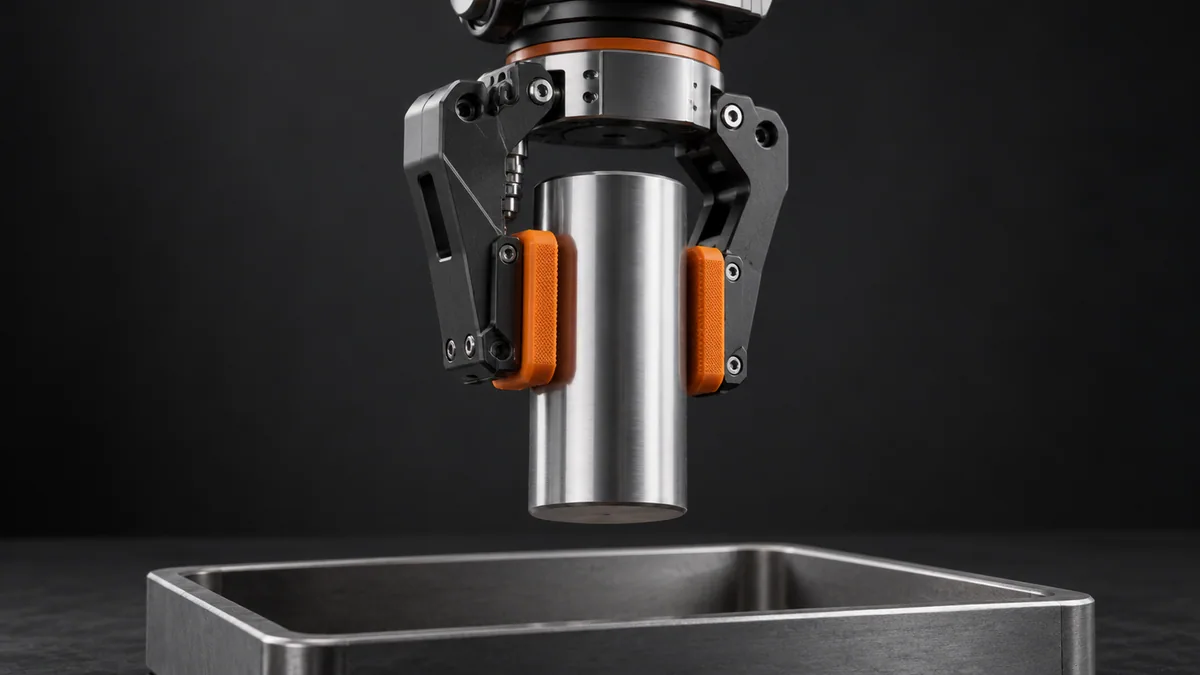
Size a two-finger gripper for a vertical lift
A part held by friction needs enough normal force to resist weight and acceleration. This simple model is useful for a two-jaw parallel gripper with equal…
Read the practical guide ↗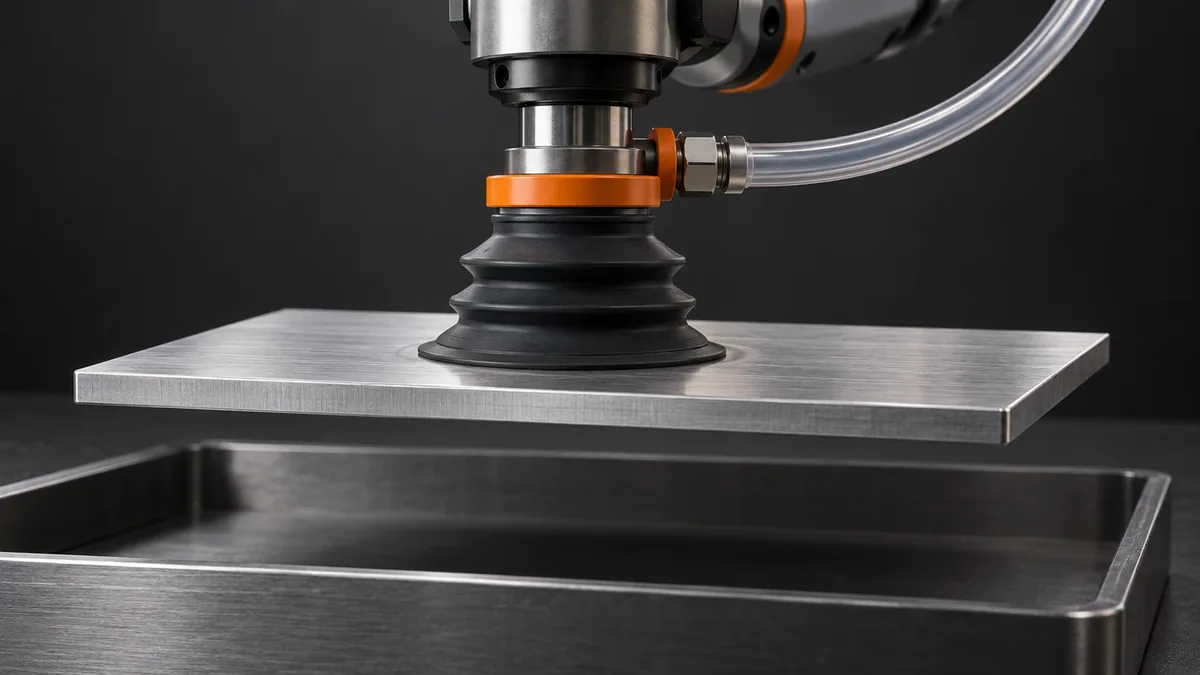
Estimate vacuum cup holding force for pick-and-place
Vacuum holding force starts with pressure difference and effective sealed area. A large cup is not enough if the surface leaks or the vacuum collapses…
Read the practical guide ↗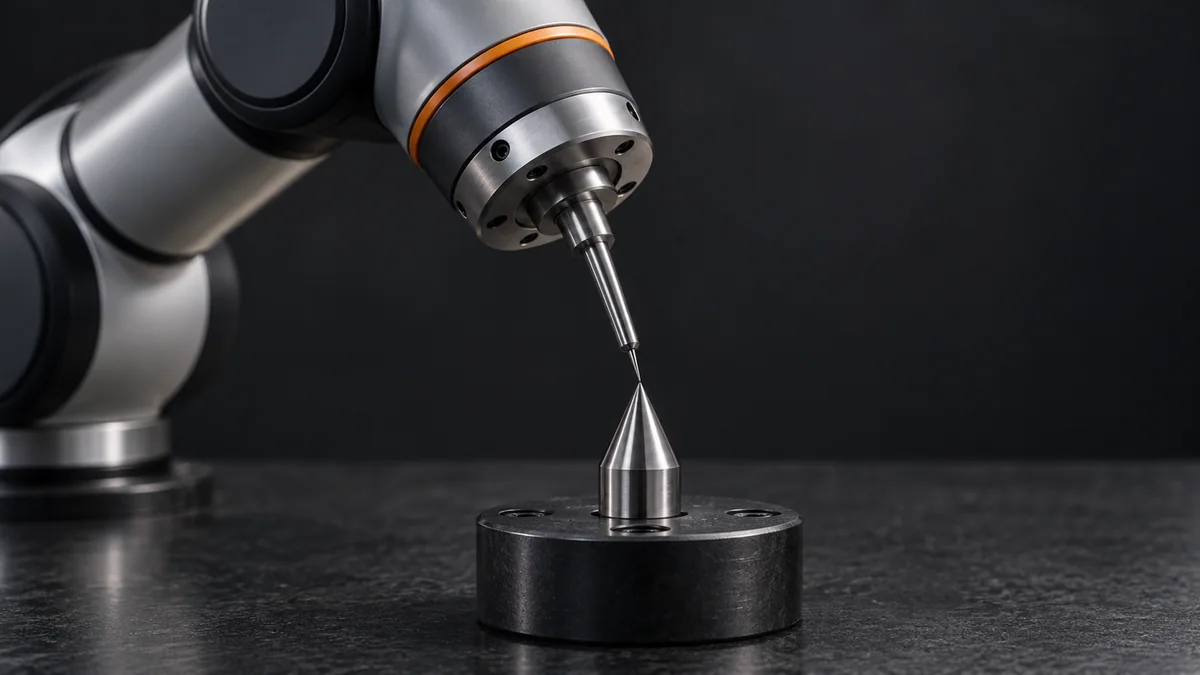
Understand tool-center-point offset errors
A TCP is the point the robot is asked to position. If its offset from the flange is wrong, changing wrist orientation moves the real tool tip away from…
Read the practical guide ↗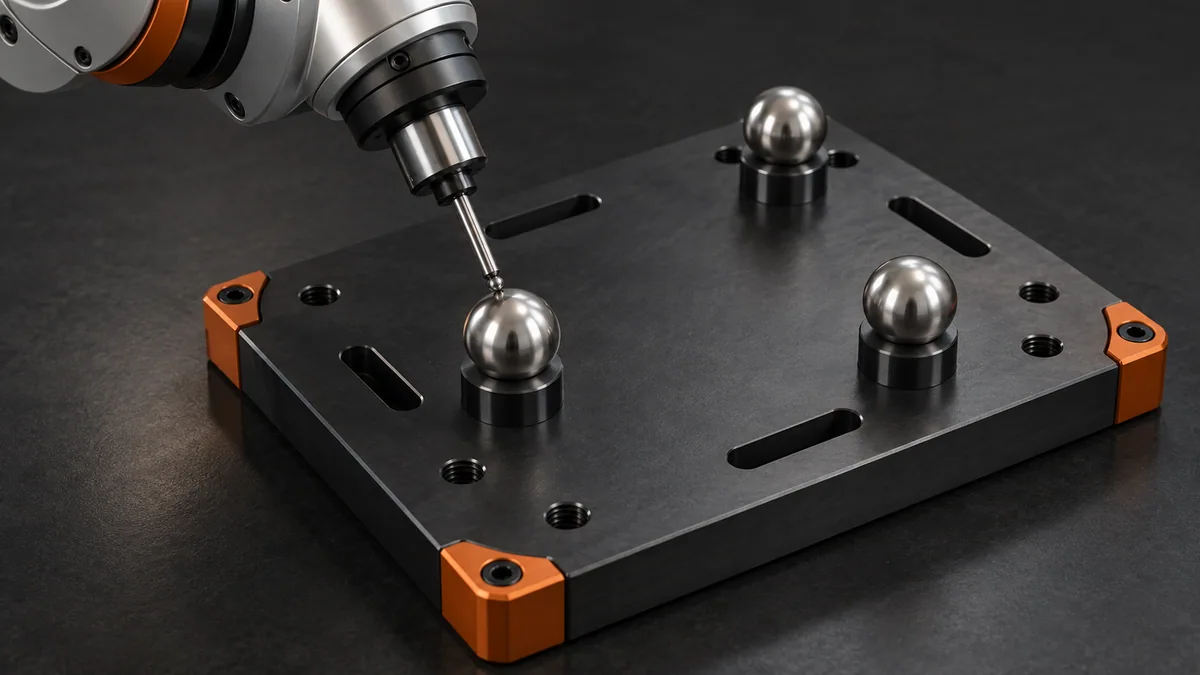
Teach a fixture frame instead of reteaching every point
A work frame describes the fixture relative to the robot. Keeping part positions in that frame means a measured fixture relocation can update many points…
Read the practical guide ↗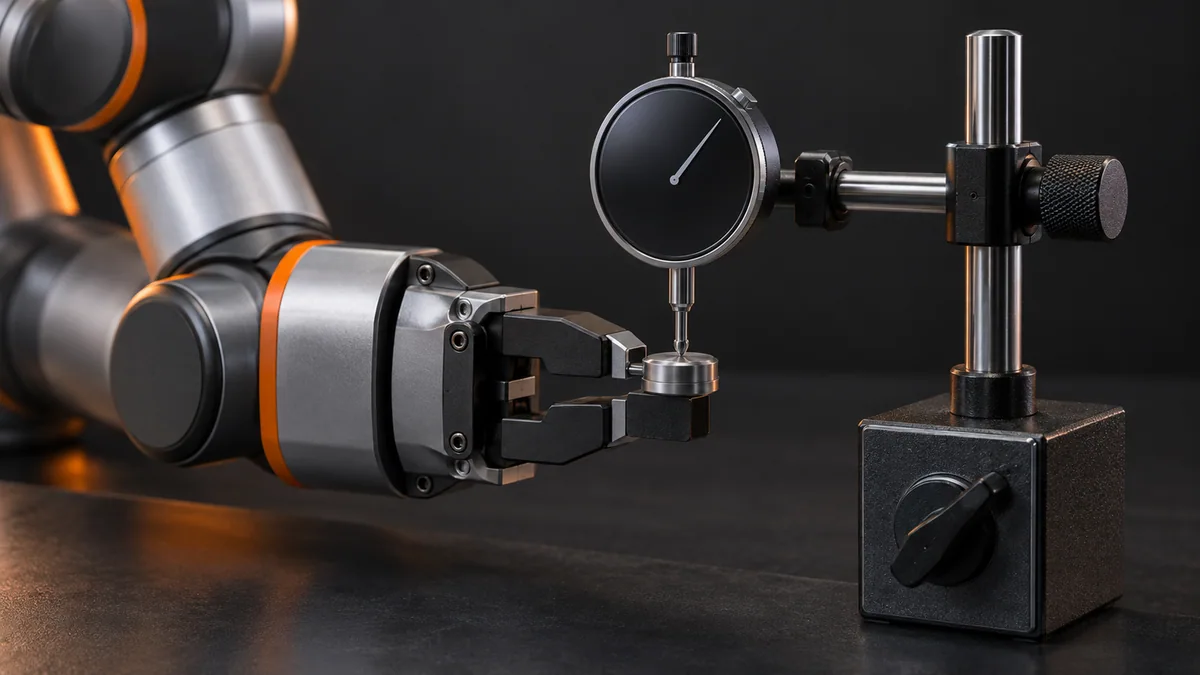
Measure repeatability without confusing it with accuracy
A robot can return to the same wrong location very consistently. Repeatability describes scatter; accuracy describes closeness to the intended location. A…
Read the practical guide ↗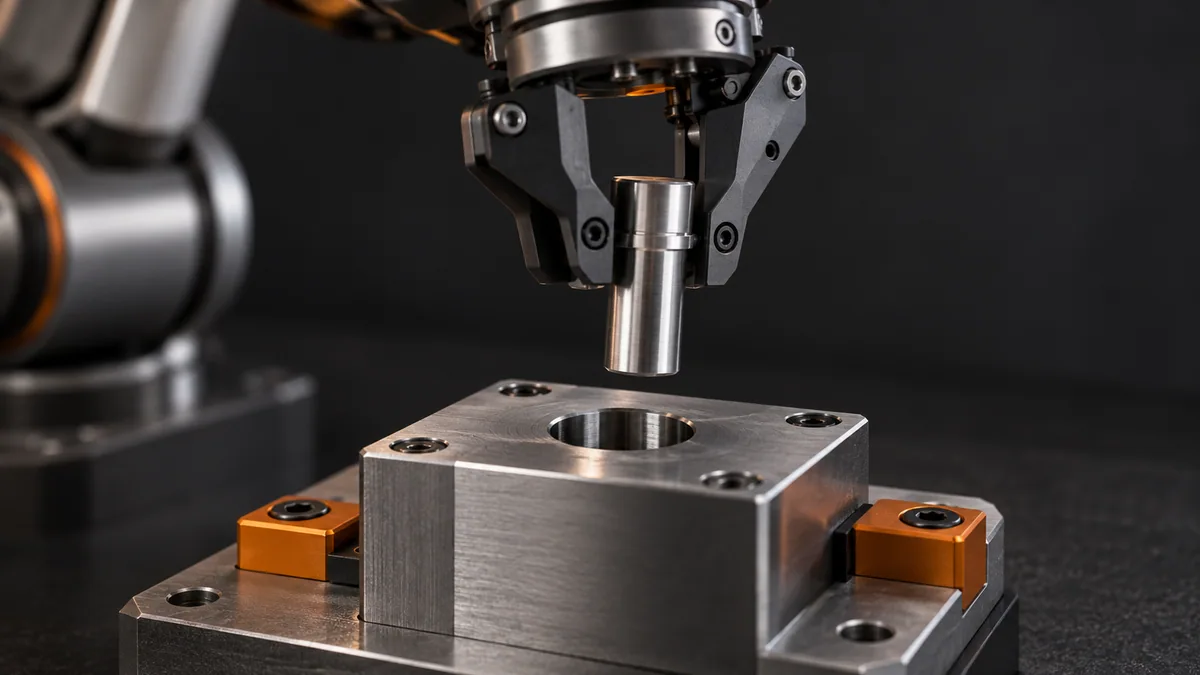
Build an error budget for a cobot insertion task
An insertion can fail even when every component seems accurate. Robot positioning, fixture location, vision and tool deflection all contribute. Combine…
Read the practical guide ↗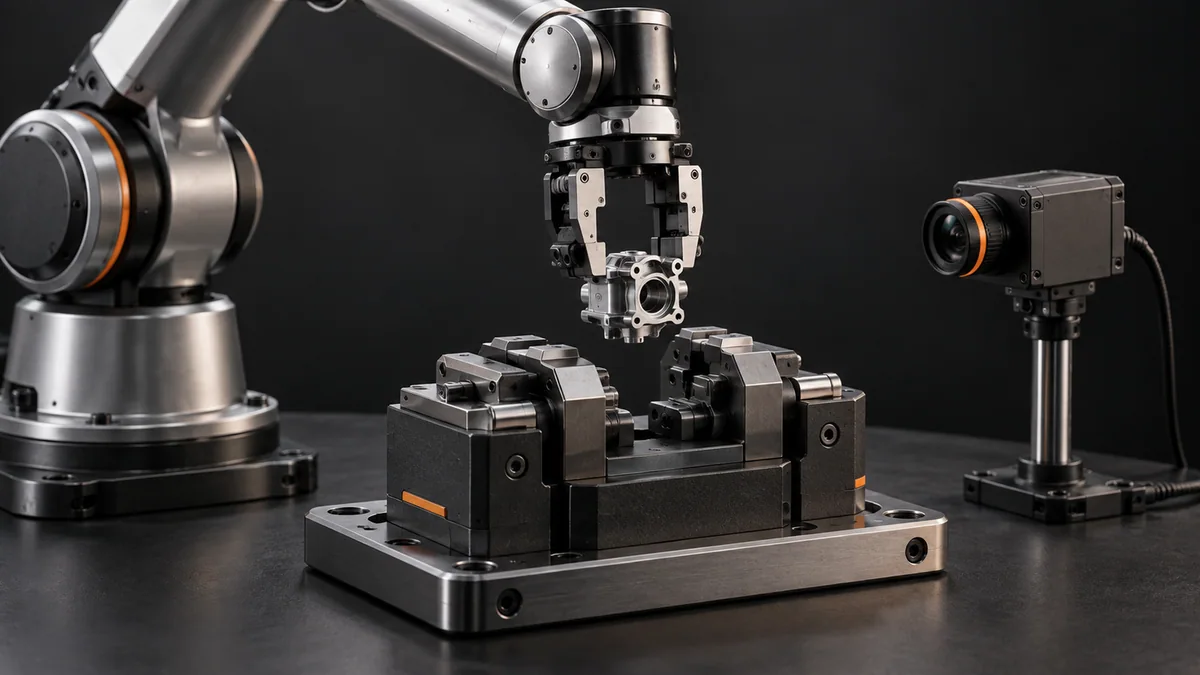
Find the bottleneck in a cobot pick-and-place cycle
Making every movement faster is rarely the best first optimization. Instrument the sequence and find the operation that controls completion. For…
Read the practical guide ↗
Predict why short robot moves never reach top speed
For short distances, acceleration and deceleration consume the entire move. Raising the speed limit then has no effect. A triangular velocity model makes…
Read the practical guide ↗
Use corner blending without cutting into a fixture
Blending avoids a full stop at intermediate waypoints, but the tool no longer passes exactly through the corner. Use a geometric model to understand the…
Read the practical guide ↗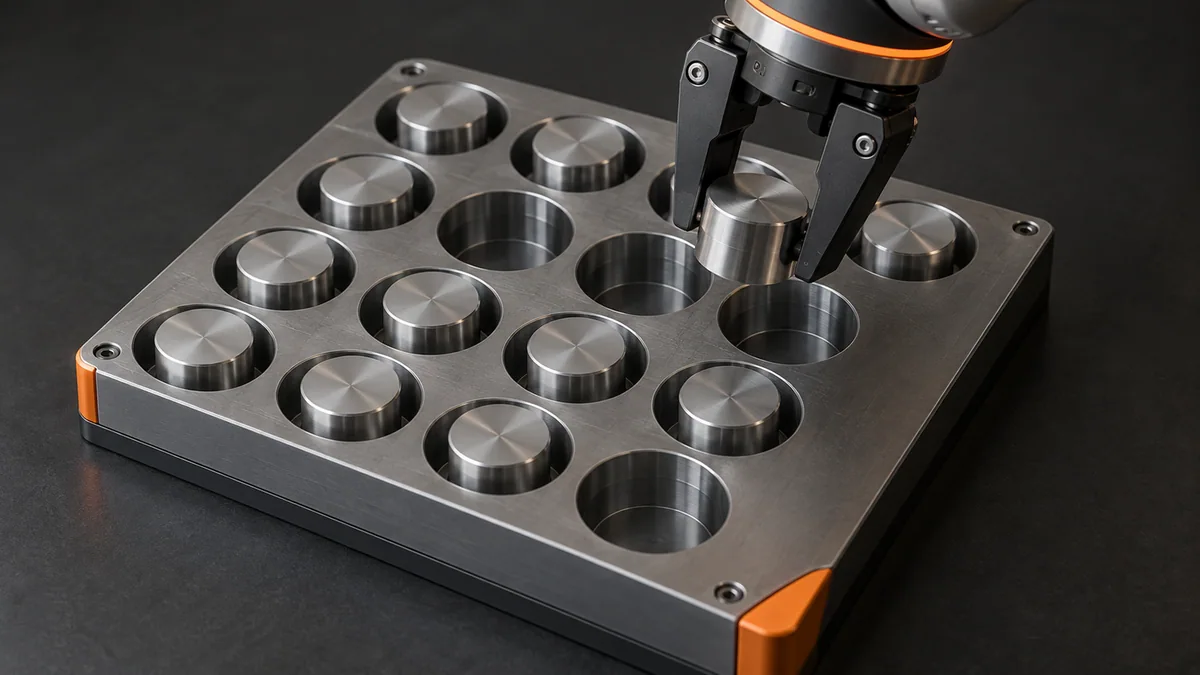
Generate a rectangular tray pattern from one taught origin
A regular tray should not require a separate manually entered coordinate for every pocket. Use row and column offsets in a fixture frame, with explicit…
Read the practical guide ↗
Set up a force-limited insertion experiment in simulation
Position control alone can jam a slightly misaligned part. A simulated compliant insertion helps you understand how stiffness and position error create…
Read the practical guide ↗
Estimate compliance from a bench force-displacement test
Tool deflection can look like a calibration error because the robot reaches the command while the tip bends away. Measure effective stiffness on a…
Read the practical guide ↗
Understand response delay in a robot stopping model
A robot continues moving between an event and the beginning of deceleration. A simple delay-plus-braking model explains why latency matters. It is…
Read the practical guide ↗
Why robot kinetic energy grows with speed squared
Reducing speed can reduce kinetic energy strongly, but energy alone does not tell you whether a contact is acceptable. Use this calculation to understand…
Read the practical guide ↗
Design a robot–PLC handshake with a bounded timeout
A handoff needs agreement about the current job, not just a start pulse. Use an explicit sequence such as idle, request, accepted, running, done and…
Read the practical guide ↗
Debounce a part-present sensor without hiding faults
A bouncing sensor can create several apparent parts from one physical arrival. Require a stable input for a defined interval, then account for the delay…
Read the practical guide ↗
Confirm a gripped part with independent process evidence
A gripper-close command confirms a command, not a successful grasp. Compare jaw position, vacuum or a part sensor with expected ranges. Ambiguous evidence…
Read the practical guide ↗
Add bounded retries to a cobot process
An automatic retry can turn a minor fault into a collision if the part state is unknown. Only retry operations that have a defined recovery pose and an…
Read the practical guide ↗
Measure useful output instead of nominal cobot speed
A fast demonstration can produce little useful output if the cell waits for material or rejects many parts. Separate availability, running speed and…
Read the practical guide ↗
Plan a cobot pilot acceptance test with honest evidence
A successful short demo is not the same as a reliable process. Define acceptance criteria before the pilot and record failures by type. A zero-failure run…
Read the practical guide ↗