What you need
Use a scale and dimensioned CAD model. Choose one flange origin and one positive-axis convention for every component.

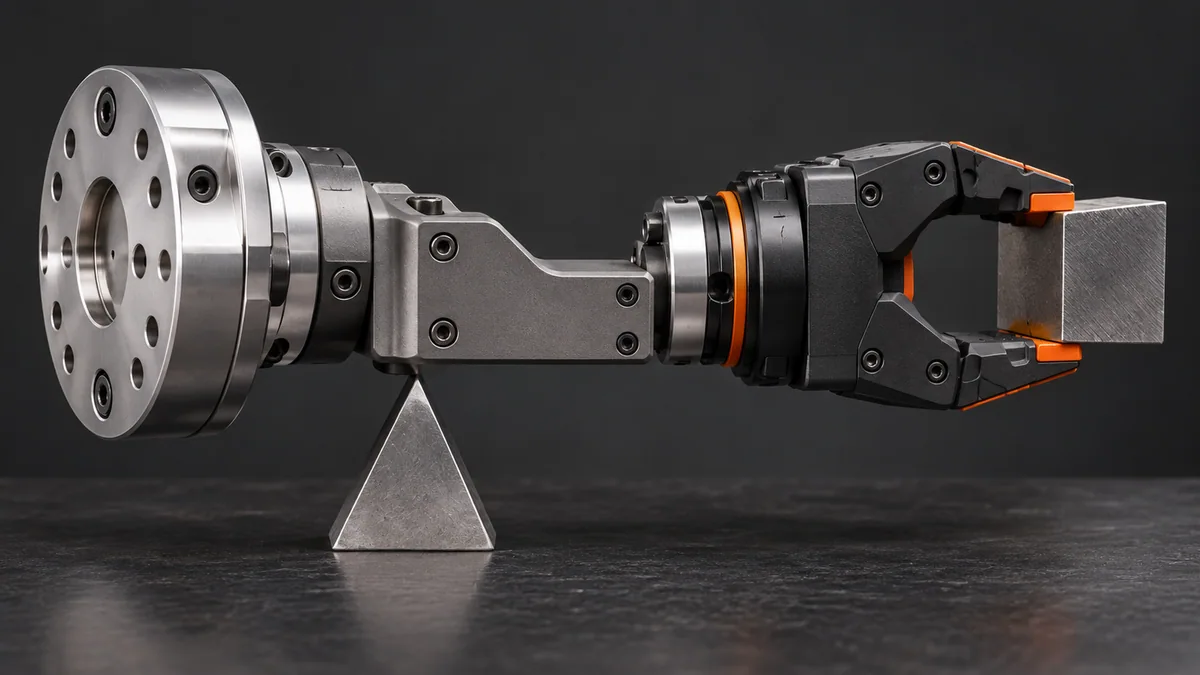
Read the diagram as a data table
| Condition or component | mm |
|---|---|
| Part at 150 mm | 114 |
| Part at 100 mm | 84 |
The calculation
x_CG = Σ(m_i × x_i) / Σm_i
m_i is component mass in kg; x_i and x_CG are distances in mm from the same origin. Use signed coordinates.
Worked example
A 0.8 kg gripper centered at 60 mm and a 1.2 kg part centered at 150 mm have x_CG = (0.8×60 + 1.2×150)/2 = 114 mm. Moving the part to 100 mm changes the combined value to 84 mm without changing mass.
Try it step by step
- List the mass and three center coordinates of every carried component, including any adapter omitted in an early model.
- Compute the mass-weighted average separately for x, y and z; do not average positions without their mass weights.
- Calculate loaded and unloaded states and record how the controller changes between them.
- Check the coordinate convention in the controller manual and validate the final configuration using its supported procedure.
How to check the result
An independent CAD mass-properties calculation should agree within the uncertainty of component dimensions and material densities.
Common mistake to avoid
The formula gives center of gravity, not rotational inertia. A physically larger tool can have the same center and very different dynamic behavior.
Reference reading
Primary references for the underlying models, APIs or application context. The worked numbers and plots above are educational calculations, not results reported by these sources.